Interactive · 1 question
The general equation of a conic is
When the coefficients take appropriate values, this equation covers:

These curves can be defined by the motion of a point, the intersection of a plane and a pair of cones (therefore the name conics), The Dandelin Spheres, and many others.
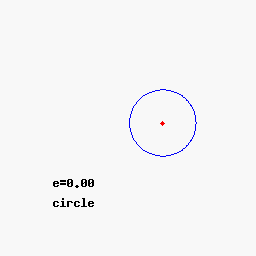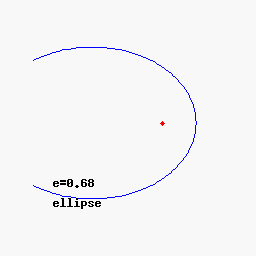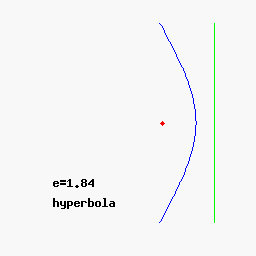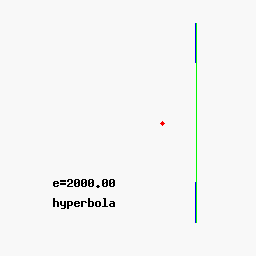
If expressed in polar coordinates, the equation would be for conics with focus at the origin, directrix at , and eccentricity .
These messy expressions just jump out of nowhere! How did people come up with it?
In short, because some people are curious.
"Genesis"
Once upon a time, probably as ancient human gazed at the twinkling stars, an obscure idea of a "point" start to form. The thing without width, length, or height... The night sky seemed like a giant canvas that is way smoother than any of the cave walls they just painted on. The sky looks just like a perfect plane. A plane and a set of fixed points. Cool.
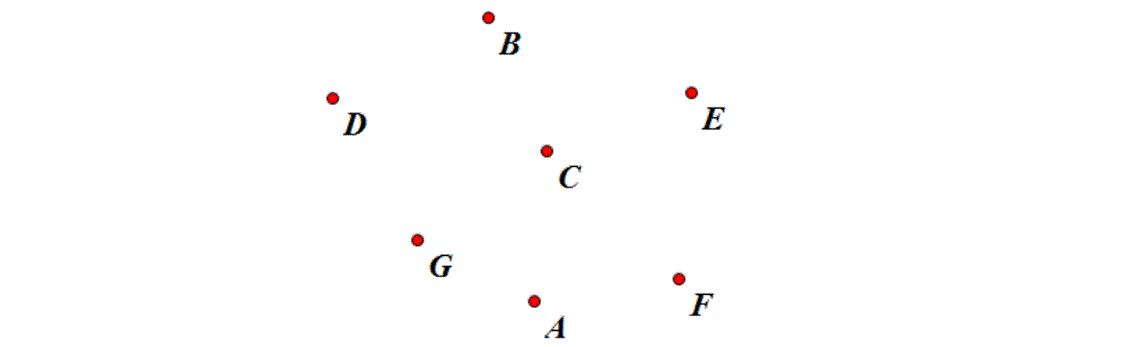
Just fixed points? What if they move? With only one point, there's nothing to determine the position of this lonely point. As if you take a dog to a giant park and set it loose, without a GPS... We cannot know very much about where it goes!
However, if you leash the dog, it can only be as far from you as the length of the leash. Similarly, having a fixed point makes the situation a lot easier to describe. Let's fix one of the two as a reference. If the distance, or the "leash" between them is always some constant length , we get a circle. Instead, if the distance is "at most ", we get a filled circle, a "disk". If we use the distance formula in Cartesian coordinates, and let the position of the fixed point be , the coordinates of the moving point will satisfy the equation , which can be rewrite as
If we use polar coordinates, and let the fixed point be the origin, the equation of the moving point would be simple:
One point is just a unruly point, and two points create a simple circle. That's when people feel bored.
Let's have a third point
If we fix two points and move the third, the motions become more interesting.
Let's call the two fixed points and , and the moving point . Last time when there's only two points and , we fixed and get a circle. What can we do about and ?
Start from simple. We have four basic operations in arithmetic: Add, subtract, multiply and divide.
What if we fix +?
We have where serves as a "radius" here. But here, both and are analogous to radii, so we write on the right side of this equation.
To simplify our equation, we can always transform the line segment to the x-axis. It will take the form
Moving one of the roots to the right side, square it, simplify, and square it again (we will cover it in more details here), it arrives at the more familiar form
Subtract, Divide, and Multiply
Similarly, when we fix we get a hyperbola, which can be transformed to the standard form When we fix we get a circle again.
The curve we get when we fix is a quartic instead of a quadratic. Besides, it can't be described as the intersection of a plane and a pair of cones. The graph looks roughly like this  This figure-8 curve is called Lemniscate of Bernoulli.
If we demand , we get one of the "degenerated conics": a straight line.
A point and a line
Three fixed points impose too much conditions that they might not be able to generate a continuous curve. Let's consider another case: a point, a straight line, and the distance from them.
When , we get a parabola. give us a ellipse again, and would be a hyperbola.
The equation of most of these curves we have just discovered are quadratics with two variables, and somehow Greeks discovered that they can also be characterized as "conic sections". To study the many shared properties of this family of curves, we list all possible terms of such a quadratic: and constant, combine them, and arrive at the general formula of conic sections.
What should we prove before saying "The general equation of a conic is "?