Parameterizing a Line Using Vectors

Before this, knowScalar Multiplication of VectorsAdding Vectors

Illustrated · 2 min

It's pretty easy to find the equation of a line in two dimensions. We just whip out the slope-intercept formula, point-slope formula, or any of the other options available to us. But what if somebody asked you to find the equation of a line in three dimensions? How about four dimensions?

If you're anything like me, you'd be a little thrown off! But have no fear, we can describe any line in any dimension using our favorite mathematical construct: vectors!

Let's take this point in 3D:
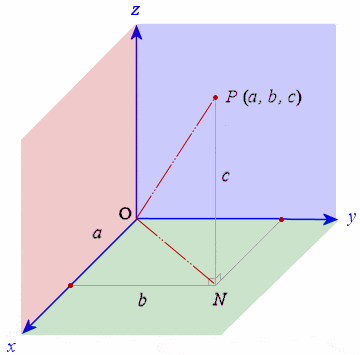
Point in 3D

For the purposes of making this a little easier to understand, let's say this point is (1, 2, 3).

Now how do we usually find lines in two dimensions? Well, we normally have two points and we want to find the equation of a line that passes through both of them. So let's say (1, 2, 3) is our first point and (3, 1, 2) is our second point.

What do we do here? We can't really use a slope-intercept formula, can we? However, let's think about the vector that goes from the first point to the second. Using our knowledge of vectors, we would know what that is: <(3-1), (1-2), (2-3)> = <2, -1, -1>.

caption

You might be thinking, "But this still doesn't help us write an equation for a line..." Hang on a second! Let's do a quick mental exercise first.

Bob the Bug is currently standing on point (1, 2, 3). In one second, he can travel to point (3, 1, 2). If Bob is traveling in a straight line, where will be the next point he goes? Well, following the pattern from the previous jump, he would go to point (5, 0, 1). In other words, he is using a vector to travel in a straight line from one point to another. If he keeps traveling using that same vector to determine his next location, he'll be going in a straight line!

Now let's make some equations for Bob's jumping.

In one second, Bob went from (1, 2, 3) to (3, 1, 2). Let's use a variable t to describe Bob's time. For the first second, t = 1.

x1=x0+2∗tx_1 = x_0 + 2*t

y1=y0+−1∗ty_1 = y_0 + -1*t

z1=z0+−1∗tz_1 = z_0 + -1*t

If you plug in t = 1, that gets you the point you want! Now try plugging in t = 2. What point do you get? It should be (5, 0, 1)!

Now let's use a more general definition to describe these vector-lines:

For two points (x0,y0,z0(x_0, y_0, z_0 and (x1,y1,z1)(x_1, y_1, z_1) and the vector <a, b, c> that travels between them, we can describe any point on the same line as:

x1=x0+atx_1 = x_0 + at

y1=y0+bty_1 = y_0 + bt

z1=z0+ctz_1 = z_0 + ct

where t is any real number.

(Please note: You can do this in any dimension you like! Can you see why?)
Read · 1 min

A line may be defined by any two distinct points on the line, but it is often more convenient to describe a line by only one point on the line and the line's direction. With the new tool of vectors, we may describe lines in any number of dimensions more easily and effectively.

Suppose that the point P=(p1,p2,...,pn)P=(p_1,p_2,...,p_n) in n-dimensional space lies on the line that we are trying to describe, and let us say that the direction vector of the line is the vector a⃗=<a1,a2,...,an>\vec{a}=<a_1,a_2,...,a_n>.

Our goal is to describe all points QQ on the line in terms of PP and a⃗\vec{a}.

We know that the vector PQ⃗\vec{PQ} is parallel to a⃗\vec{a} if and only if PQ⃗=ka⃗\vec{PQ}=k\vec{a} for some real number k.

Thus, QQ lies on the line if and only if Q⃗=P⃗+ka⃗\vec{Q}=\vec{P}+k\vec{a}, where P⃗\vec{P} and Q⃗\vec{Q} are the position vectors of PP and QQ, respectively.

Thus, all points on the line can be described as follows: Q⃗=<p1,p2,...,pn>+k<a1,a2,...,an>=<ka1+p1,ka2+p2,...,kan+pn>\vec{Q}=<p_1,p_2,...,p_n>+k<a_1,a_2,...,a_n>\\=<ka_1+p_1,ka_2+p_2,...,ka_n+p_n>.

We have successfully parameterized the line! Here, kk is called the parameter, as all of the coordinates of QQ are described as functions of kk.

Be warned that a given line (or more generally, any curve at all) has infinitely many parameterizations. This may be seen by multiplying the direction vector a⃗\vec{a} by some new nonzero scalar to produce a vector parallel to a⃗\vec{a}; this new vector is equally valid as a direction vector for the line.

Illustrated · 1 min

A Different Definition of a Straight Line

What is a straight line? Simple question. What is a straight line in terms of vectors?

Consider a line APAP, parallel to vector b⃗\vec{b}. Take another vector a⃗\vec{a}, which starts from the origin,OO. Vector r⃗\vec{r} is such that it starts from the origin and ends at point PP. The diagram is shown in below (Figure 1).

Figure 1: Straight line using Vectors

In this diagram, line AP{AP} can now be written as:

r⃗\vec{r} - a⃗\vec{a}

Also, APAP is parallel to b⃗\vec{b}. Thus,

APAP = ttb⃗\vec{b} (As APAP is a linear multiple of b⃗\vec{b} )

Combining both the equations, we get:

r⃗\vec{r} - a⃗\vec{a} = ttb⃗\vec{b}

∴r⃗=a⃗+tb⃗\therefore \vec{r} = \vec{a} + t\vec{b} for some multiple or (more correctly) parameter tt.

The equation above is the Vector equation of a straight line.

Type a concept, like “slope” or “photosynthesis”.

↑ ↓ to choose · Enter to openSearch explanations and problems