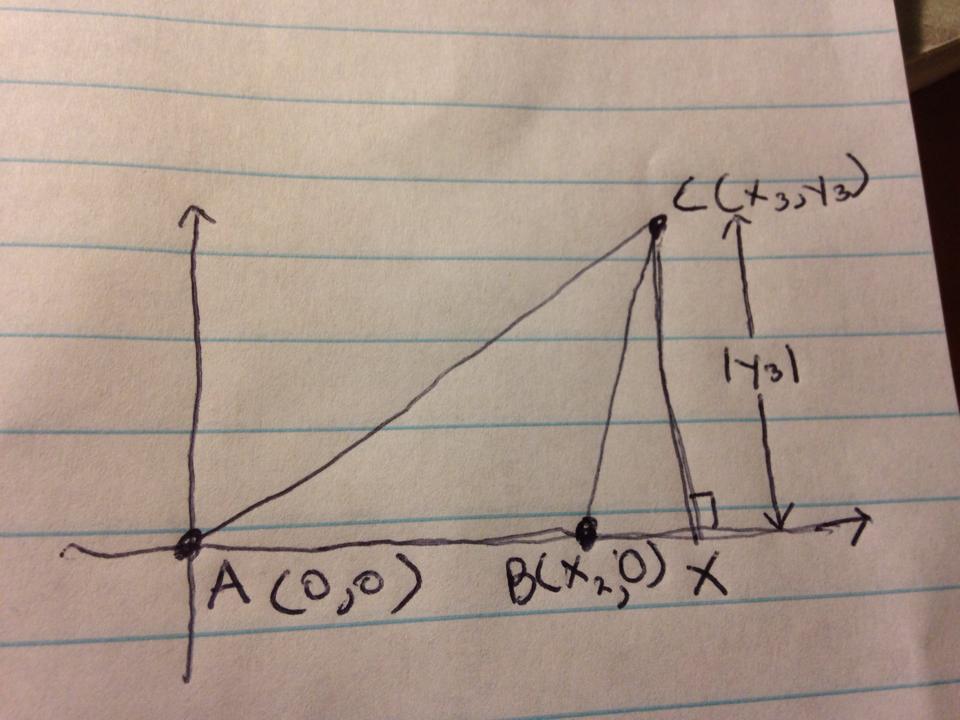It's always important to define our terms. Even when the meaning of a term seems obvious, like "area," giving a definition helps us work with "area" in a consistent way. It can also help us understand the concept of area better.
Before you read on, try to think of a definition of area.
It's hard to do, isn't it? Area should be some kind of measure of the size of a figure, but it's hard to give a definition. Instead, let's start by listing some things that should be true about area:
(1) If we put two figures together, the area of the new figure should be the sum of the areas of the original two.
(2) If we cut a figure in two, the sum of the areas of the two resulting figures should be the area of the original one.
(3) If a figure fits inside of another figure, the first figure has a smaller area than the second.
Do you agree that area should satisfy each of these? Are there any other properties that area should have?
Some might give a fourth property:
(4) A rectangle with dimensions a×b has area ab.
However, some might disagree! Not that they disagree that the rectangle has area ab, but it's worthwhile to point out that if we wanted to, we could define area such that any rectangle with dimensions a×b has area 2ab. It would be weird, but it's not inconsistent.
What do you think about this?
This all suggests the following definition:
For any figure that can be broken down into rectangles with dimensions a1×b1, a2×b2,…, an×bn
the area of the figure is a1b1+a2b2+⋯+anbn.
There are two big issues with this definition. Can you identify them?
One issue is there might be multiple different ways to break down a figure into rectangles. We need to prove that our concept of area is well-defined, in other words, that it gives the same number regardless of how we break down our figure into rectangles. We won't prove this here; see Hilbert's book for a discussion.
A second issue is that most figures can't be broken down into rectangles! (For example, a triangle!)
Can you think of what we should do about this?
If you're imagining filling figures with infinitely tiny rectangles, you're on the right track, but we need a way to handle this without referring to infinitely tiny rectangles. Here's a hint:
For any figure, think of the many figures that fit inside that figure, and that can be broken down into rectangles. Some of these figures have an area that's just barely smaller than the area of the original figure. To see this, imagine replacing the diagonal or curved sides with staircase-like chains of horizontal and vertical segments.
Now can you think of how to define area for figures that can't be broken down into rectangles?
Here's a definition:
The area of a figure is the least upper bound of the areas of all figures that fit inside that figure, and that can be broken down into rectangles.
So, that's it! Keep on using areas like you're used to, but remember that it all comes from a definition something like this one.
What if we have a more complicated region like the Batman curve?
We "can" break it up into small rectangles (perhaps squares, for simplicity). See Matt's great explanation here for more details.
Another way to think about this: suppose we plot a figure on a piece of graph paper with "unit" squares. Again, we can think about the Batman curve.
Then a "good approximation" for the area of the figure is just the number of unit squares inside! (And if we make the squares smaller and smaller, we can get better and better approximations!)
This is the key idea behind any formal definition of area. For example, see here.
In fact, for "lattice polygons" (polygons in the plane with integer coordinates), we can say something even more precise: see Pick's theorem.
The concept of area is sometimes introduced by talking about the "amount of paint" required to cover a certain figure in the plane. Thus a square of side 2 feet would need four times as much paint to cover it as a square of side 1 foot, a circular disc of radius 1 foot would need a little over three times as much, and so on. This simple idea of the "amount of paint" suggests to us several properties that area should have, which we could use as axioms; for example, the property that the area of a figure made up of two separate pieces is the sum of the areas of the individual pieces. However, if our theory is to be precise, we need to start one stage further back, and to say what kinds of "figures" we intend to find the area of.
In school geometry we apply the concept of area to simple figures like squares, triangles, and circles. These are all examples of subsets of a Euclidean plane P, and our first thought might well be that an area should be assigned to every subset of P. But this approach runs into difficulties. The problem is that a general subset of P might be very unlike the simple ones from which we build up our intuition about areas. Consider for example the following curious subset of the plane R2:K={(x,y)∣0≤x,y≤1 and x and y are rational numbers}.(Remember that a rational number is just a fraction p/q, where p and q are integers.) Now for any rational number, there are irrational numbers arbitrarily close to it; and for any irrational number, there are rational numbers arbitrarily close to it. How then am I to work out how much paint is needed to cover the set K? If I put a spot of paint on each point of K, then however small the spots are they will overlap and fill up the whole unit square. If I decide to be more careful and only to put down paint completely inside K, then I will leave everything unpainted. (In more formal language, which will be introduced later, the outer content of K is 1, while the inner content of K is 0.) So it looks as though I do not have a clear idea what should be the area of so strange a set as K.
To avoid this problem, it is necessary to abandon the assumption that every subset of the plane can be given a definite area. The subsets to which the area axioms will apply are bounded polygonal regions, which are defined in terms of half-planes.
Definition.A closed half-plane Hin a Euclidean planePis a subset represented in a Cartesian coordinate system byH={(x,y)∣ax+by+c≥0}where a, b, and c are constants, and not both of a and b are zero.
An open half-plane is a subset represented in a Cartesian coordinate system byH={(x,y)∣ax+by+c>0}where a, b, and c are as above.
A line in the plane P separates it into two open half-planes; if the line has equation ax+by+c=0, then the two half-planes are given by ax+by+c>0 and −ax−by−c>0. Closed half-planes can be obtained by taking the union of the open half-planes with the bounding line.
Definition.A polygonal region in a Euclidean plane P is a subset P of P which can be obtained from finitely many half-planes (closed or open) by the operations of union(∪)and intersection(∩).
For example, if H1,…,H4 are half-planes, then the sets(H1∩H2)∪(H3∩H4),H1∩H3∩H4,H4∪(H2∩(H1∪H3))are all polygonal regions. It is clear from the definition that the union or intersection of two polygonal regions is again a polygonal region.
If X and Y are two subsets of the plane, their set-theoretic differenceX\Y is the intersection of X with the complement of Y, that isX\Y={x∈X∣x∈/Y}.Using the fact that the complement of an open half-plane is a closed half-plane and vice versa, it is easy to give a proof that the set-theoretic difference of two polygonal regions is again a polygonal region.
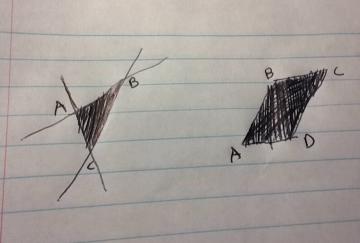
Example. Let ABC be a proper triangle in the plane P. The line AB then divides P into two open-half planes, one of which contains the point C; call this half-plane HC. Similarly let HA be an open half-plane containing A and bounded by the line BC and let HB be an open half-plane containing B and bounded by the line AC. The intersection HA∩HB∩HC is then a polygonal region called the interior of the triangleABC.
Interior of a triangle, and of a parallelogram.
It is a little pedantic to keep up with the distinction between the triangle ABC and the polygonal region which is its interior, and we will not worry too much about this. In particular, we will refer to the "area of the triangle ABC" rather than the strictly accurate "area of the interior of triangle ABC".
Example. Let ABCD be a parallelogram. There is then an open half-plane HAB bounded by CD and containing A and B, and there are similarly defined open half-planes HBC, HCD, and HDA. The intersection of these four half-planes, HAB∩HBC∩HCD∩HDA, is called the interior of the parallelogramABCD. It is tempting to say that the interior of the parallelogram ABCD is the union of the interiors of the triangles ABC and CDA; this is not strictly accurate, because the diagonal AC does not belong to the interior of either triangle. We will see, however, that the inaccuracy makes no difference from the point of view of area.
The area of a rectangle will be of particular interest to us. A rectangle is a parallelogram whose adjoining sides are perpendicular. Its interior may also be defined as a set given by {(x,y)∣a<x<b,c<y<d} in an appropriate Cartesian coordinate system.
Definition.Let S be a subset of a Euclidean plane P. The diameter of S is the least upper bound of the distances between points of S; in symbols,Diam(S)=sup{∣PQ∣∣P,Q∈S}.The diameter is a positive number, possibly +∞. If the diameter is finite the set S is called bounded. it is clear that the union of two bounded sets is bounded, and that the intersection of a bounded set with any set is bounded.
Proposition.The interior of a triangle, or of a parallelogram, is a bounded set.
Proof. It is enough to give a proof for a parallelogram, since any triangle is contained in a parallelogram. Choose one vertex of the parallelogram as an origin, and let a and b be vectors along the sides, so that the interior consists of all points with position vectorsr=λa+μb:0<λ,μ<1.Then∣r∣2≤λ2∣a∣2+2λμ∣a∣∣b∣+μ2∣b∣2≤(∣a∣+∣b∣)2by the Cauchy-Schwarz inequality. So, if r1 and r2 are the position vectors of two points in the interior, then by the triangle inequality ∣r1−r2∣≤2(∣a∣+∣b∣). So the diameter is finite.□
Axioms for area
Formally speaking, area is a new undefined term in an axiomatic system for geometry; the areaA(P) of a bounded polygonal region P is a non-negative real number. The properties of area are given by the three axioms below.
Axiom (Area Invariance Axiom). Let P be a bounded polygonal region. Let T be an isometry of the plane P, mapping P to a new polygonal reigion T(P). Then A(P)=A(T(P)).
Axiom (Area Addition Axiom). Let P1 and P2 be bounded polygonal regions that are disjoint (that is, P1∩P2=∅). ThenA(P1∪P2)=A(P1)+A(P2).**Axiom (Area Normalization Axiom).**The area of a rectangle of sides a and b is ab.
From the addition axiom we can immediately deduce the monotonicity property: if P1 and P2 are bounded polygonal regions, and P1⊆P2, then A(P1)≤A(P2). For since P1⊆P2, we can write P2 as the disjoint union of P1 and the difference set P2\P1. From the addition axiom, we deduce thatA(P2)=A(P1)+A(P2\P1)≥A(P1)using the fact that the area of P2\P1 is non-negative.
We can also obtain a more general form of the addition axiom that applies when the sets involved are not necessarily disjoint.
Proposition.Let P1 and P2 be bounded polygonal regions. ThenA(P1∪P2)=A(P1)+A(P2)−A(P1∩P2).Proof. Write P1∪P2 as the disjoint union of P1 and P2\P1 to getA(P1∪P2)=A(P1)+A(P2\P1).Write P2 as the disjoint union of P1∩P2 and P2\P1 to getA(P2)=A(P1∩P2)+A(P2\P1).Combine these two equations to obtain the result.□
We frequently will want to apply the addition axiom to a polygonal region made up of simpler regions such as triangles. When we put triangles together there tend to be some line segment left over at the edge; the next result assures us that this doesn't matter from the point of view of area.
Lemma.A (bounded) line segment has zero area.
Proof. A line segment of length l can be enclosed in a rectangle which can be as thin as we like; for instance, in a rectangle of sides l+ϵ and ϵ, where ϵ can be any small positive quantity. So the area of the line segment must be less than or equal to the area of the rectangle, which is ϵ(l+ϵ). This can be made as small as we like it by making ϵ small, so the area must be zero.□
Proposition.The area of a right-angled triangle ABC is 21∣AB∣∣BC∣.
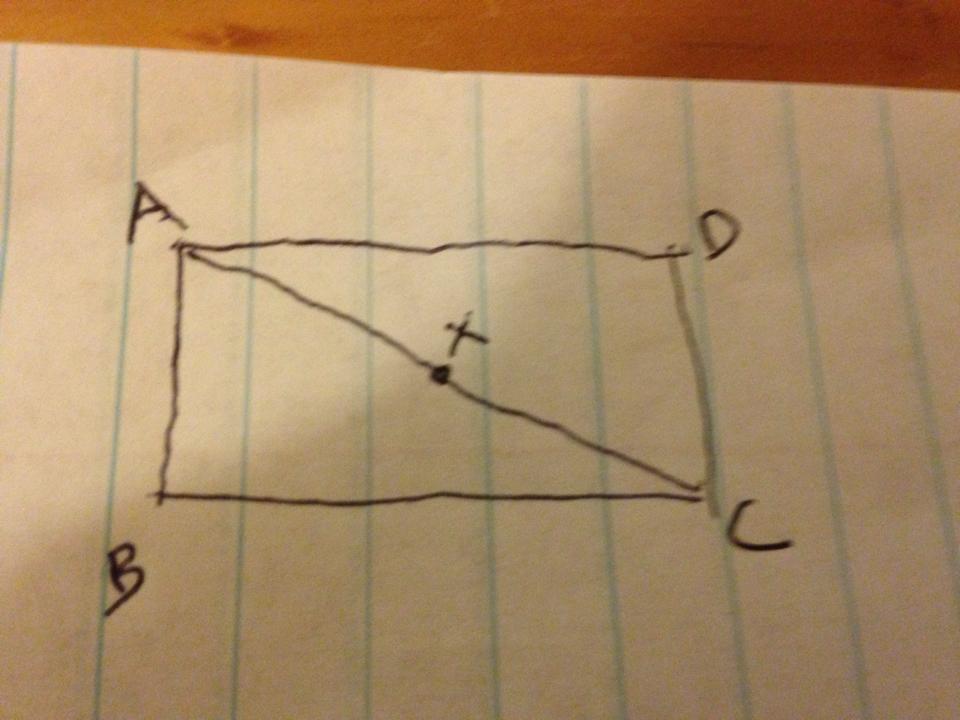
Proof. Let X be the midpoint of the hypothenuse AC, and let CDA be the triangle obtianed from ABCD by central inversion in X. Then AB=DC and AD=BC, so ABCD is a parallelogram; in fact it is a rectangle, because AB is perpendicular to BC.
Area of a right-angled triangle.
Now the interior of ABCD is made up of three disjoint pieces: the interior of ABC, the interior CDA, and the line segment AC. The line segment has zero area by our lemma, and the two triangles have the same area because they are congruent by central inversion. So by the addition axiom,A(ABC)=21A(ABCD)=21∣AB∣∣BC∣.□We can calculate the area of a general triangle from that of a right-angled triangle:
Proposition.The area of a triangle ABC is equal to 21∣AB∣∣CX∣, where ∣CX∣ is the altitude from C to AB.
Remark. This proposition really gives us three different ways of calculating the area of a triangle because any one of the three vertices may be chosen as the one from which we measure the altitude. The proposition is often stated in words as "the area of a triangle is equal to half the base times the altitude".
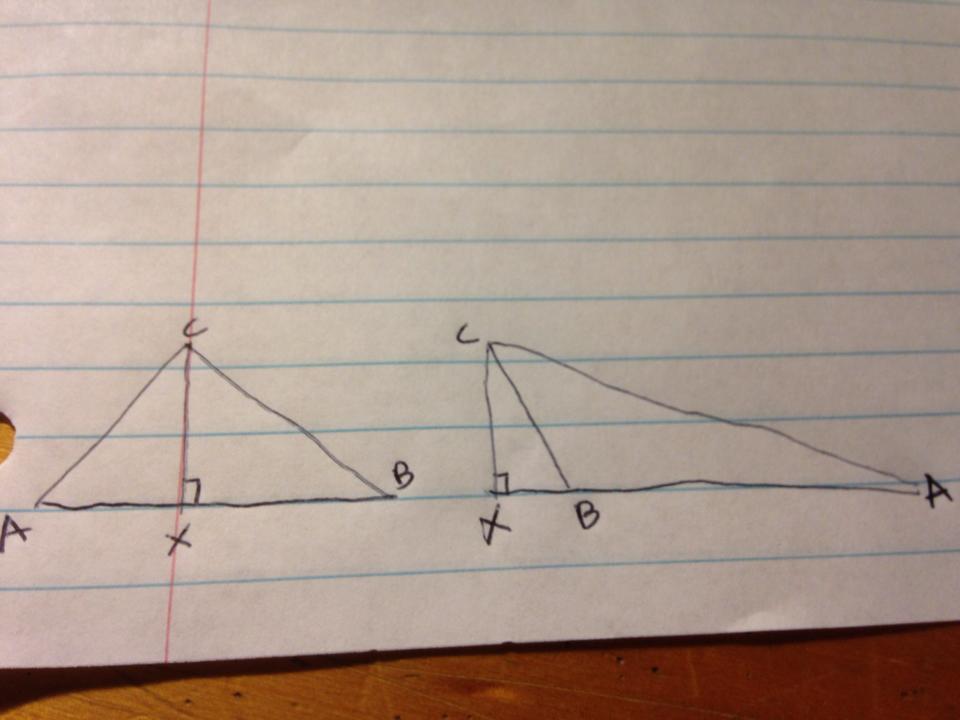
Proof. There are two cases to consider; either X is between A and B, or it is not.
The area of a triangle.
If X is between A and B, then the right-angled triangles ACX and CXB are disjoint. SoA(ABC)=A(ACX)+A(CXB).Use the previous result to work out the areas of the right-angled triangles ACX and CXB, gettingA(ABC)=21∣AX∣∣CX∣+21∣XB∣∣CX∣=21∣AB∣∣CX∣because ∣AB∣=∣AX∣+∣XB∣.
If X is not between A and B, then one of A and B is between the other one and X. Assume without loss of generality that B is between A and X. Then the triangles ABC and BCX are disjoint, and soA(ABC)=A(ACX)−A(BCX)=21∣AX∣∣CX∣−21∣BX∣∣CX∣=21∣AB∣∣CX∣because now ∣AB∣=∣AX∣−∣BX∣.□
Corollary.The area of a parallelogram ABCD is ∣AB∣∣CX∣, where CX is the altitude from C to AB.
Proof. This is clear on dividing up the parallelogram into two triangles which are congruent by central inversion in the midpoint M.□
The formula for the area of a triangle can be reinterpreted in several different ways. One interpretation makes use of an orientation for the plane P. Recall that an orientation for P is an operation u↦u⊥ which rotates a vector u through 2π radians.
Proposition.Let A, B, and C be points in an oriented Euclidean plane P, with AB=u and AC=v. ThenA(ABC)=21∣u⊥⋅v∣,and if D is the unique fourth point that makes ABCD a parallelogram, thenA(ABCD)=∣u⊥⋅v∣.Proof. We have already seen that the area of a parallelogram is twice the area of the corresponding triangle, so we need only prove the formula for triangles. To do this, introduce a Cartesian coordinate system with origin A and x-axis along the line AB. Then B will have coordinates (x2,0) and C will have coordinates (x3,y3).
Vector formula for the area of a triangle.
The altitude ∣CX∣ is equal to ∣y3∣, so that the area of the triangle is 21∣x2y3∣. On the other hand, the dot product u⊥⋅v can be worked out as a determinant,u⊥⋅v=x20x3y3=x2y3.So A(ABC)=21∣u⊥⋅v∣, as required.□
Remark. If P is a plane in a three-dimensional oriented Euclidean space S, and n is a unit normal vector to P, then an orientation can be defined on P by u⊥=n×u. So the area formula becomesA(ABC)=21A(ABCD)=21∣[n,u,v]∣=21∣u×v∣.Suppose now that the three points A, B, and C have Cartesian coordinates (x1,y1), (x2,y2), and (x3,y3) respectively. Then the area formula givesA(ABC)=±21x2−x1y2−y1x3−x1y3−y1=±211x1y11x2y21x3y3.It's established that this determinant vanishes if and only if the three points are collinear. The sign (+ or −) can be explained in terms of orientation (exercise left to the reader).
Yet another expression for the area of a triangle is in terms of the lengths of its sides. If we use the standard notation a, b, and c for the sides and A, B, C for the angles of the triangle ABC, the the altitude ∣CX∣ is equal to bsinA, by trigonometry in the right-angled triangle CXA. Using the formula sinA=bc2s(s−a)(s−b)(s−c),this gives us Heron's formula:A(ABC)=s(s−a)(s−b)(s−c),where s=21(a+b+c) is the semiperimeter.
Example. Suppose that you have a loop of string which you want to stretch out into a triangle enclosing as large an area as possible. A few experiments will quickly convince you that long thin rectangles are not a good idea; you want as short and fat a triangle as possible, and in fact an equilateral one seems to be best. This is a simple example of an isoperimetric problem, to enclose the greatest area within a specified parameter. We can use Heron's formula to check that the solution to this problem is indeed an equilateral triangle.
We will need the celebrated arithmetic-geometric mean inequality, which states that for any n positive numbers x1,…,xn their geometric mean is always less than or equal to their arithmetic mean (exercise left to the reader), that is (x1…xn)1/n≤n1(x1+⋯+xn); equality occurs only if x1=⋯=xn. Applying this inequality to the three numbers (s−a), (s−b), and (s−c), we find that(s−a)(s−b)(s−c)≤271(3s−a−b−c)3=27s3.(Remember that a+b+c=2s.) Therefore by Heron's formula,A(ABC)≤33s2,and equality occurs if and only if s−a=s−b=s−c, which is to say that a=b=c and the triangle is equilateral.
The method of exhaustion
To be written...
The question of consistency
In the Geometry part of Expii, when the axioms for geometry were introduced, we mentioned the question of whether these axioms are consistent. They can be shown to be consistent by exhibiting a model. If you are not satisfied that the "intuitive picture" of geometry is sufficiently precise to qualify as a model, then to prove consistency you need to construct a model in terms of other mathematical objects. In the Geometry part we showed, as a byproduct of our study of vectors and dot products, how this can be done for the axioms of geometry that we had previously introduced.
The same question of consistency can be asked about the axioms of area, and again there are two possible answers. One can say that the concept of area is such a clear part of "intuitive geometry" that no further justification for the axioms is required, or one can try to construct a model for them. In this case, to construct a model means to define (by means of some kind of formula) the area of a bounded polygonal region, in such a way that the area so defined satisfies the addition, invariance, and normalization axioms.
At first sight this does not seem too hard. After all, we already have a formula,A(ABC)=±21x2−x1y2−y1x3−x1y3−y1=±211x1y11x2y21x3y3,whereby we can define the area of a triangle, and it is easy to see that any bounded polygonal region can be decomposed (give or take a few line segments) into the union of finitely many disjoint triangles. So why can we not simply define the area of a bounded polygonal region as the sum of the areas of the triangles making it up, and thereby prove the consistency of the axioms of area?
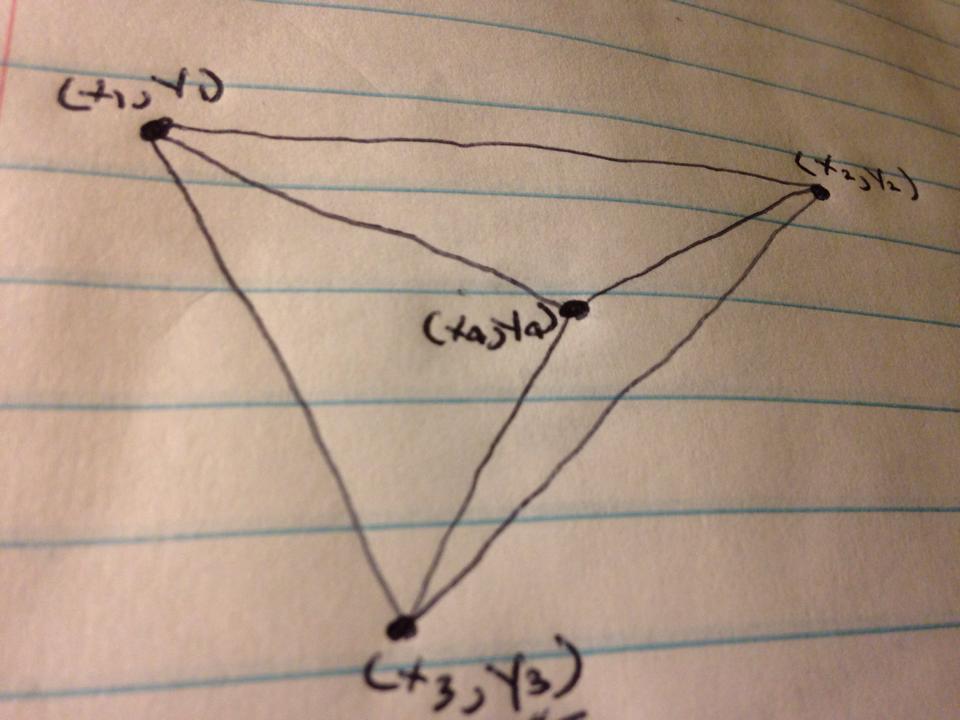
The problem is that a bounded polygonal region can be written as the union of nonoverlapping triangles in many different ways. Even a triangle itself can be written as the union of three smaller triangles.
A triangle decomposed into three smaller triangles.
How do we know that we will arrive at the same answer by adding up the areas of the triangles in all these different decompositions? Remember that we are not allowed to use the addition axiom to say that the answer will always be the area of the polygonal region in question, because the consistency of this axiom is precisely what we are trying to prove! We have to show directly from the formulas that the answer is always the same, and this is obviously going to be a messy business. Here is how we might go about it for the triangle illustrated in the figure above. Consider the 4×4 determinant11x1y111x2y211x3y311x4y4.This determinant is zero because the first two rows are the same. But expanding by the first row, we get1x2y21x3y31x4y4−1x1y11x3y31x4y4+1x1y11x2y21x4y4−1x1y11x2y21x3y3=0.Taking account of the orientation of the triangles, we can see that this tells us that the area of the large triangle is equal to the sum of the areas of the three smaller ones.
A general proof of the consistency of the area axioms can be given along these lines, but is rather long winded. I have decided to omit it, but if you would like to see the details, you can find them in various books (Pogorelov's Geometry comes most readily to mind).
Remark. A different, although related, question is whether our axioms for area can be strengthened in any way while still preserving consistency. Around 1900 the French mathematician Lebesgue discovered that one can obtain a consistent theory of area satisfying the axiom of "countable additivity", which is a strengthening of the addition axiom: if (Xn)n=1∞ is a sequence of mutually disjoint sets, thenA(n=1⋃∞Xn)=n=1∑∞A(Xn).Lebesgue's theory allows one to assign areas to many more sets than the theory that we have developed; in particular it assigns the area zero to the noncontented set K introduced at the very beginnning:K={(x,y)∣0≤x,y≤1 and x and y are rational numbers}.But its chief importance is not in geometry but in analysis, where it allows one to develop a theory of integration which is "complete" in a sense which Riemann integration is not. Very roughly, the relationship between Riemann integration and Lebesgue integration is the same as that between the rational numbers and the real numbers.